Simulate Before You Deploy

Build Mobile Robots, Block by Block

A graphical low-code engineering platform for designing motion, navigation, control logic, and robot applications—without starting from scratch.

Engineer More Robots. Repeat Less Work.

Configure instead of coding from scratch, turn mechanical parameters into working control, and reuse proven engineering across robot variants and customer projects.

Build Once, Adapt Across Robot Variants

Reuse proven function blocks, data types, and program logic across robot models and customer projects.

Build Robots Like Building Blocks

Assemble robot logic visually with low-code, function-block-based development.

From Mechanics to Working Navigation

Enter chassis parameters once and automatically generate matching motion and navigation parameters.

Standards-Based and Engineer-Friendly

Support LD, FBD, and ST based on IEC 61131-3, helping PLC engineers become productive faster.

Configure Communication, Not Protocol Code

Integrate third-party hardware through graphical configuration and use named signals directly in robot logic.

Everything You Need to Engineer a Mobile Robot

Configure hardware, develop robot logic, control motion and navigation, and commission complete robot systems—all in one engineering environment.

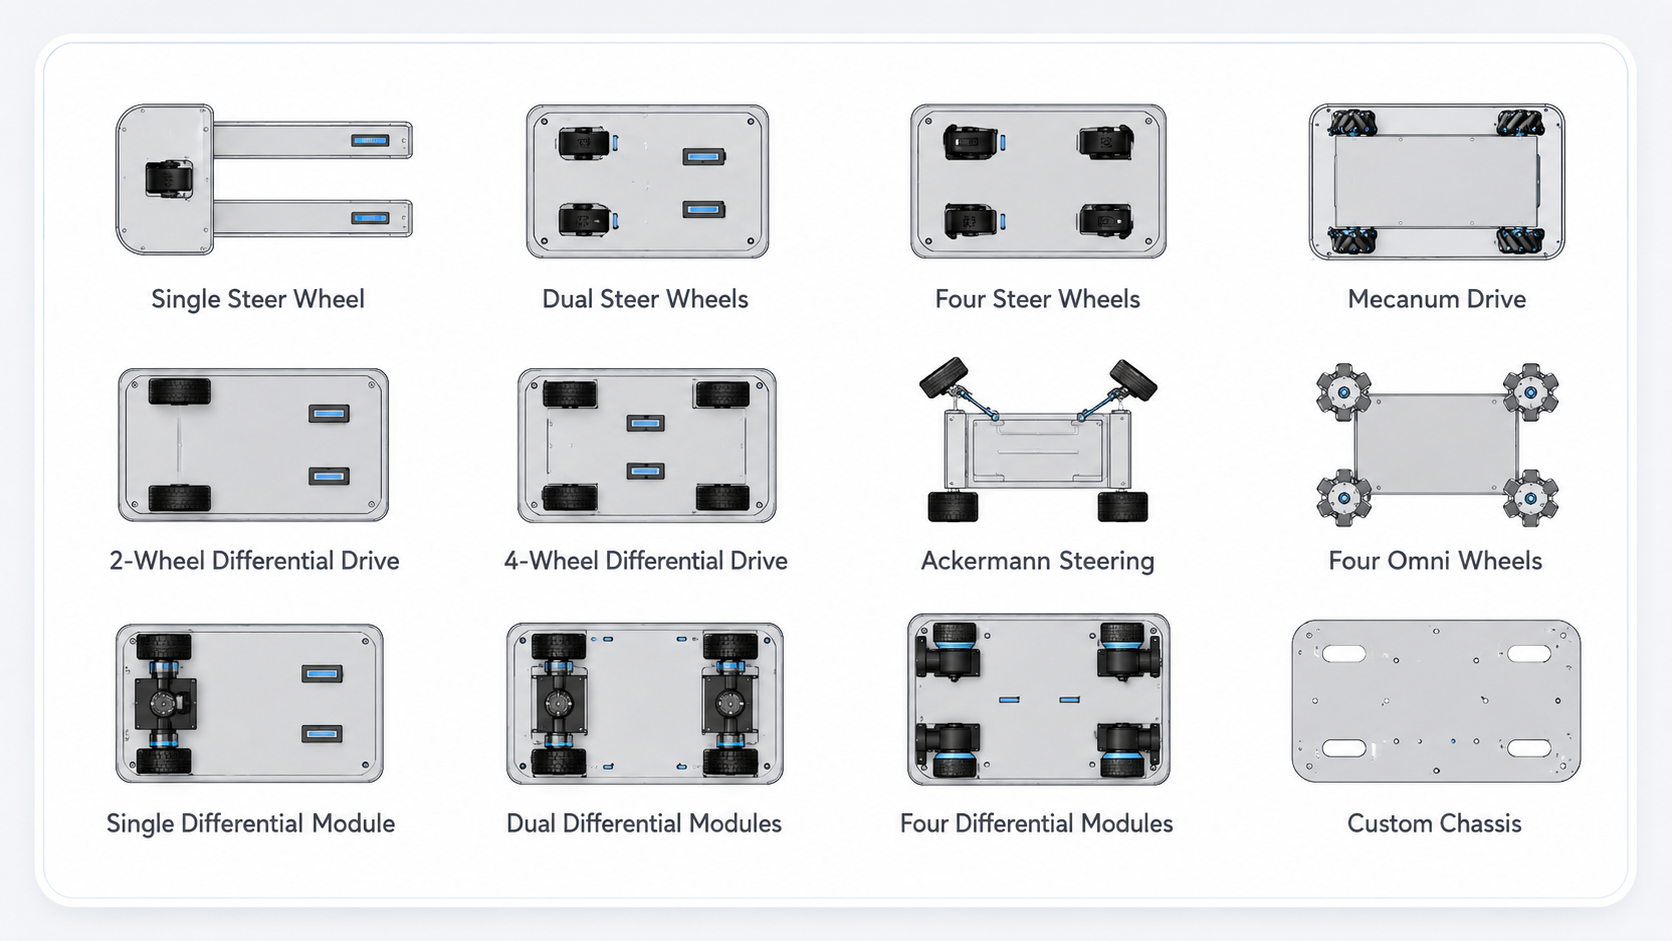
Robot Configuration

Configure 20+ chassis kinematic models—from differential and Mecanum to multi-steer-wheel and articulated platforms—through a guided, step-by-step workflow.
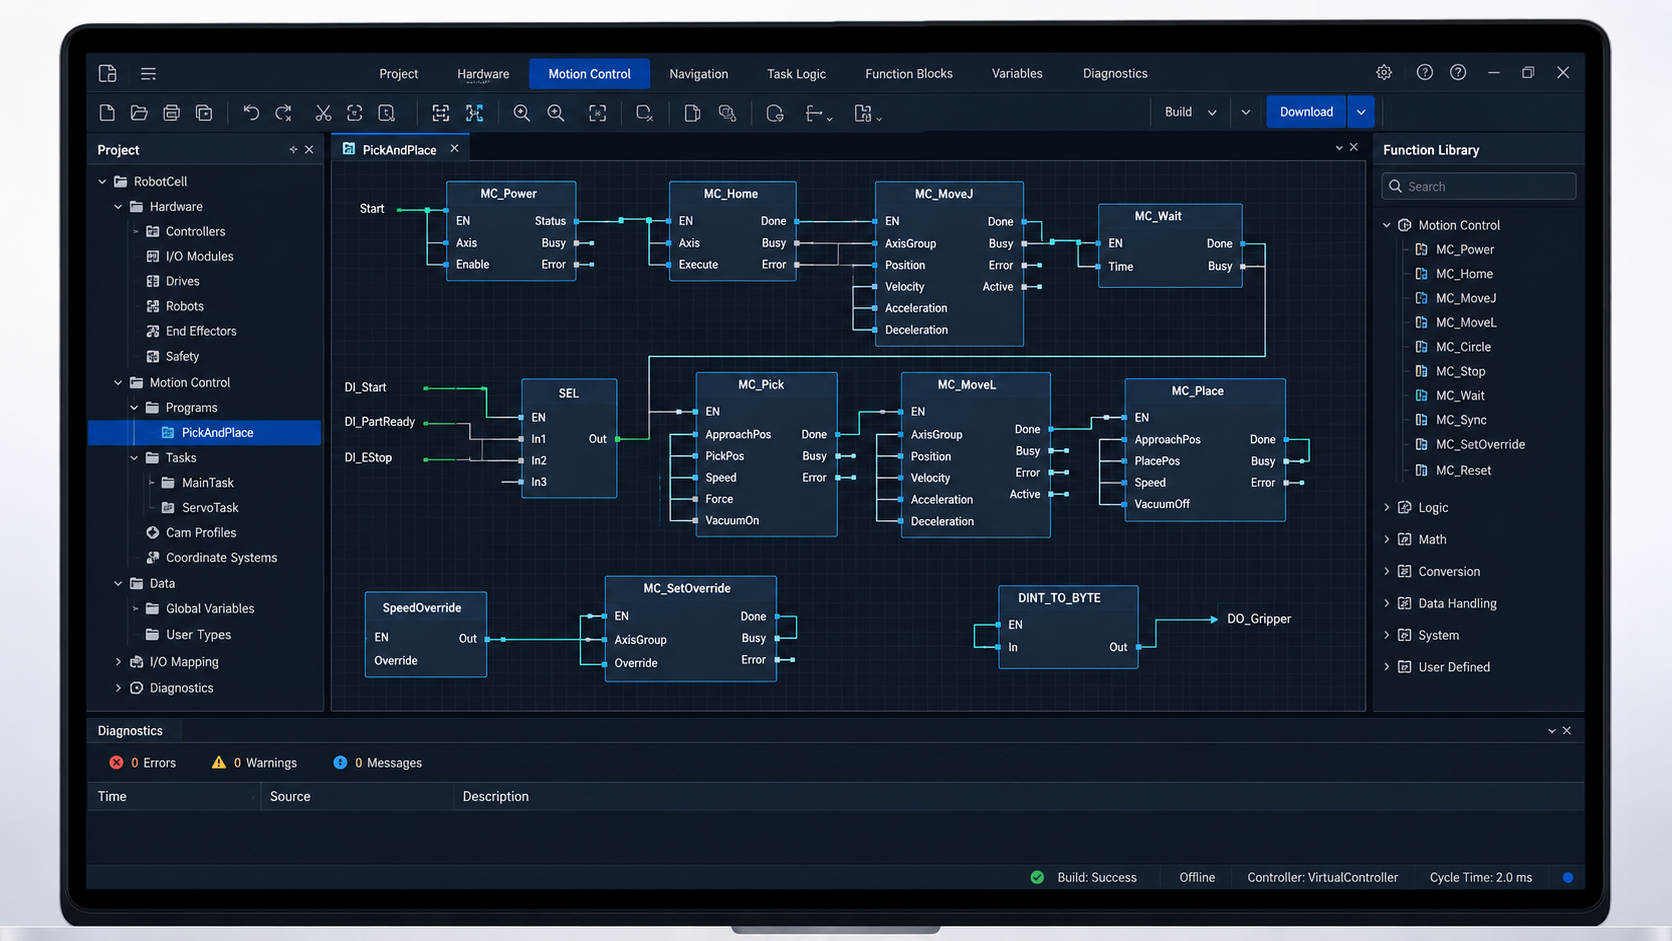
Hardware & Communication Integration

Connect drives, sensors, I/O, and third-party devices over CAN, TCP/UDP, serial, and Modbus, with device-level communication status and diagnostics.
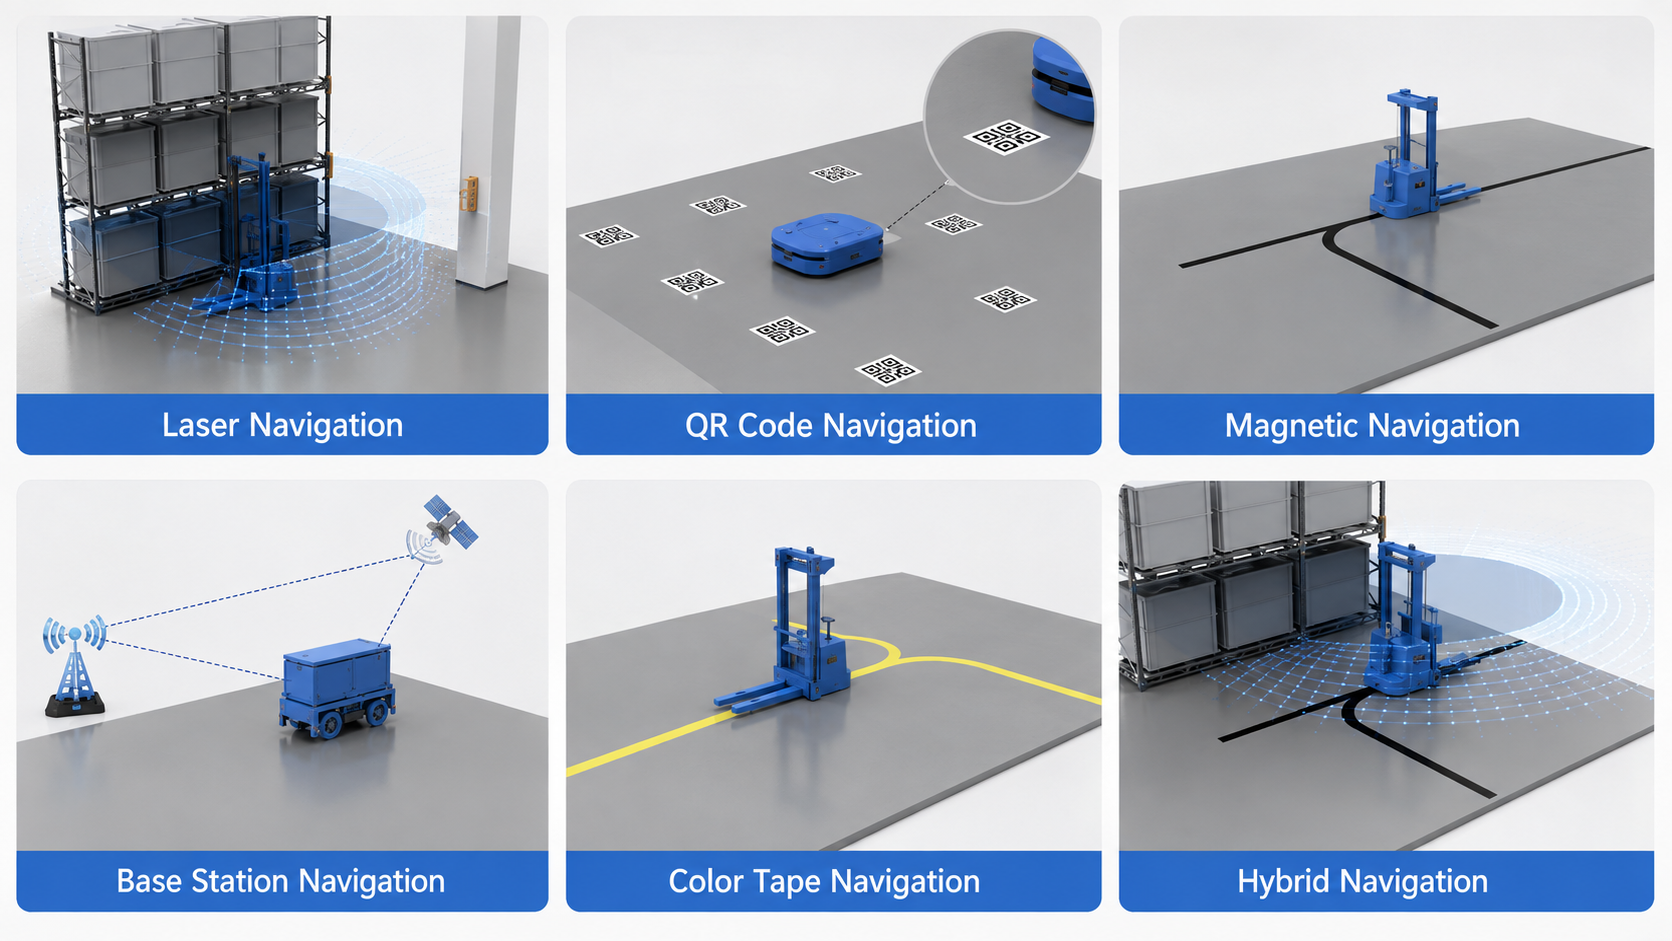
Navigation & Motion Control

Support laser, magnetic, QR code, color-band, electromagnetic, and hybrid navigation, with motion control adapted to each supported chassis model.
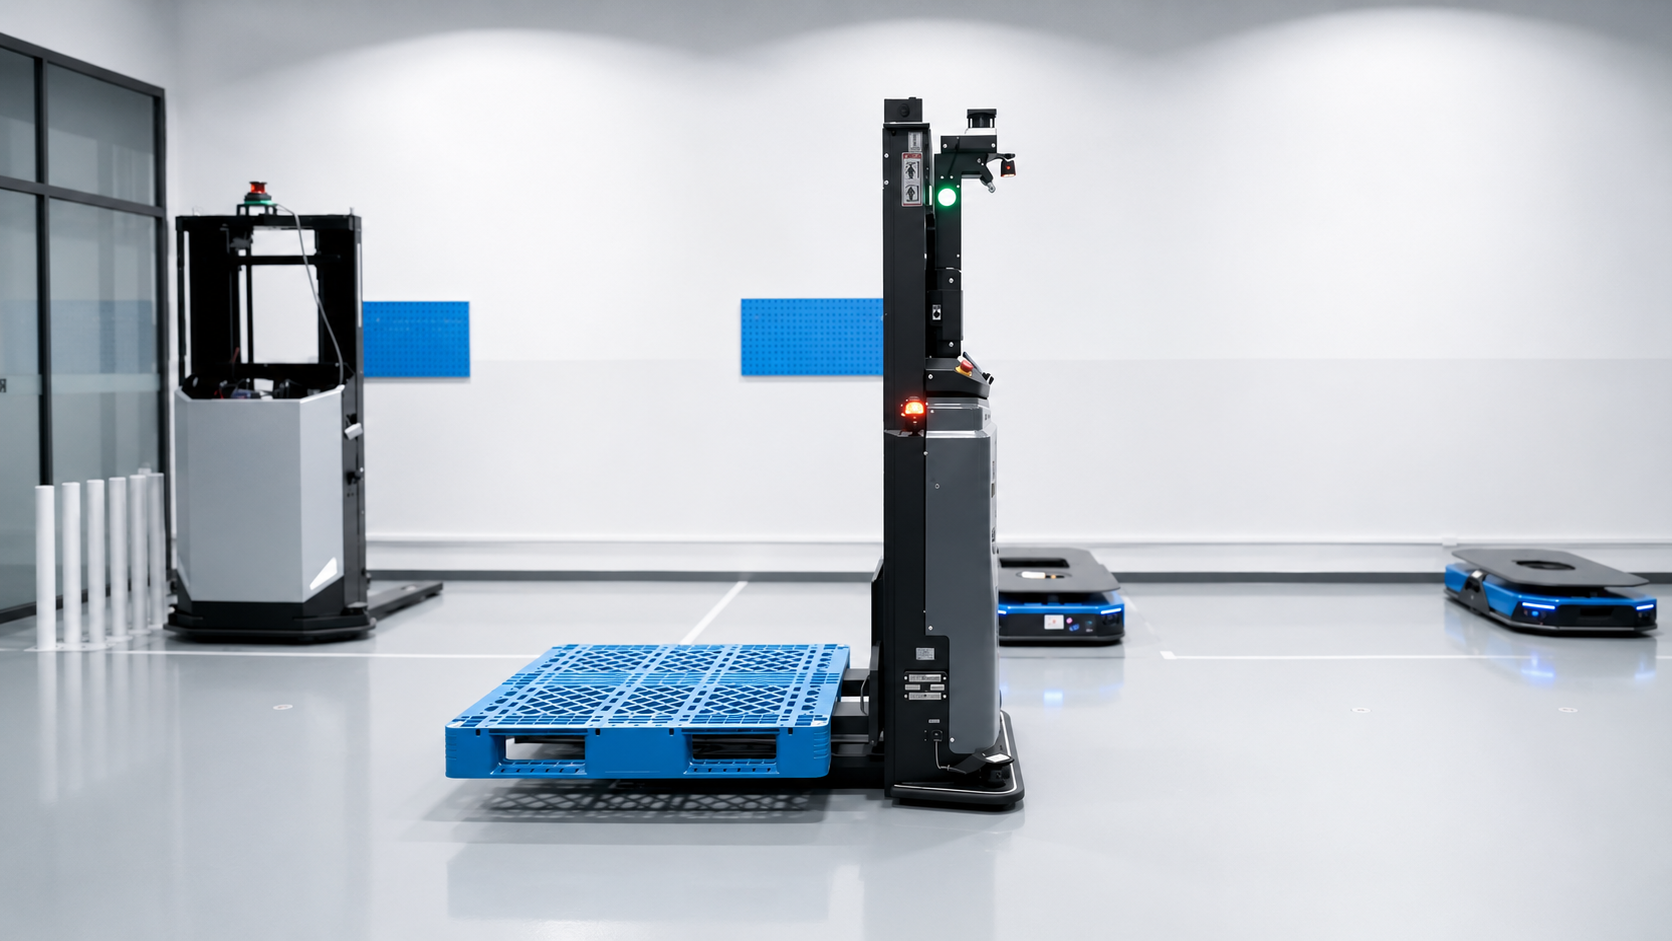
Application & Task Control

Implement task handling, charging, multiple fork configurations, multi-robot coordination, and control of peripherals and external devices.
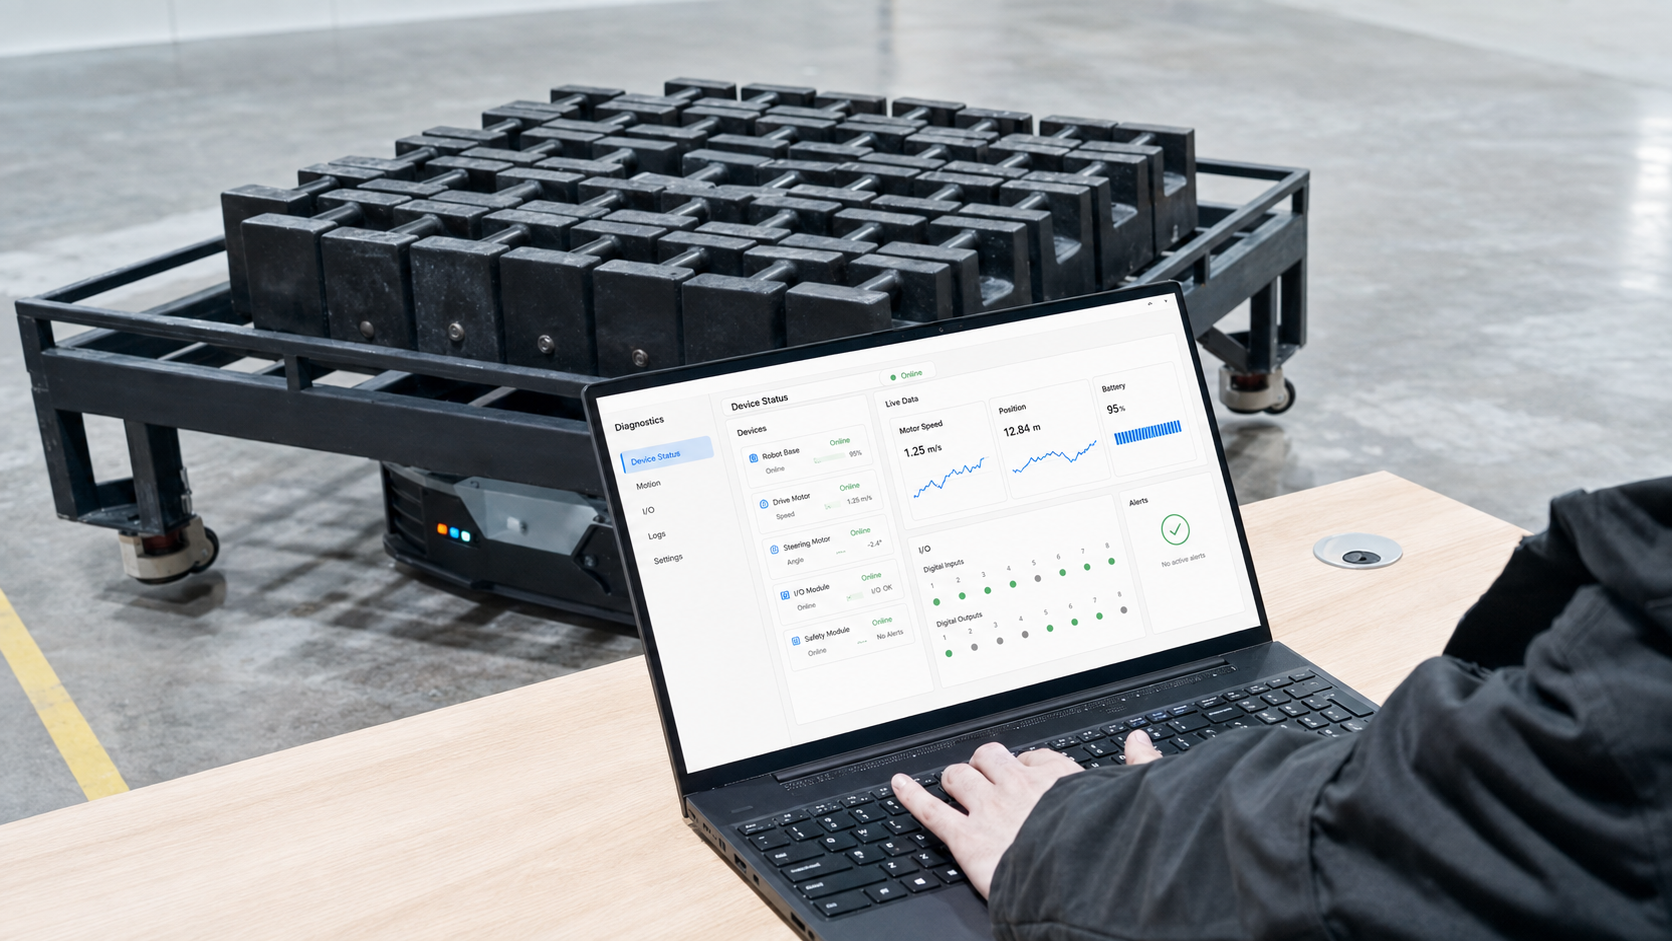
Commissioning & Diagnostics

Compile and download projects, monitor variables and task execution online, and trace configuration, communication, and runtime issues.
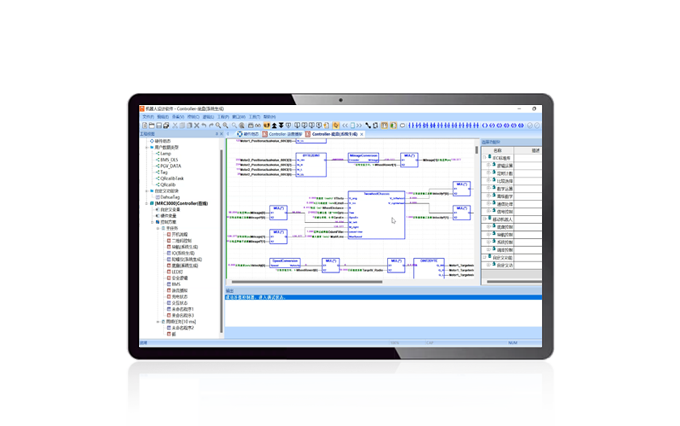
KCONBOT Software Ecosystem

An integrated software portfolio covering robot engineering, site deployment, fleet operations, configuration, testing, and diagnostics.

Robot Engineering

Configure robot hardware and develop motion, navigation, safety, and application logic.
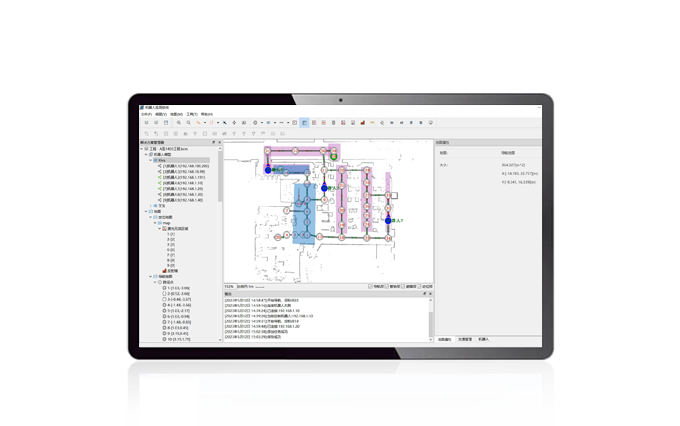
Site Deployment

Build robot models, maps, routes, work areas, and deployment configurations.
Fleet Operations

Manage routing, tasks, traffic, and real-time operations across mixed robot fleets.

Scroll to Top