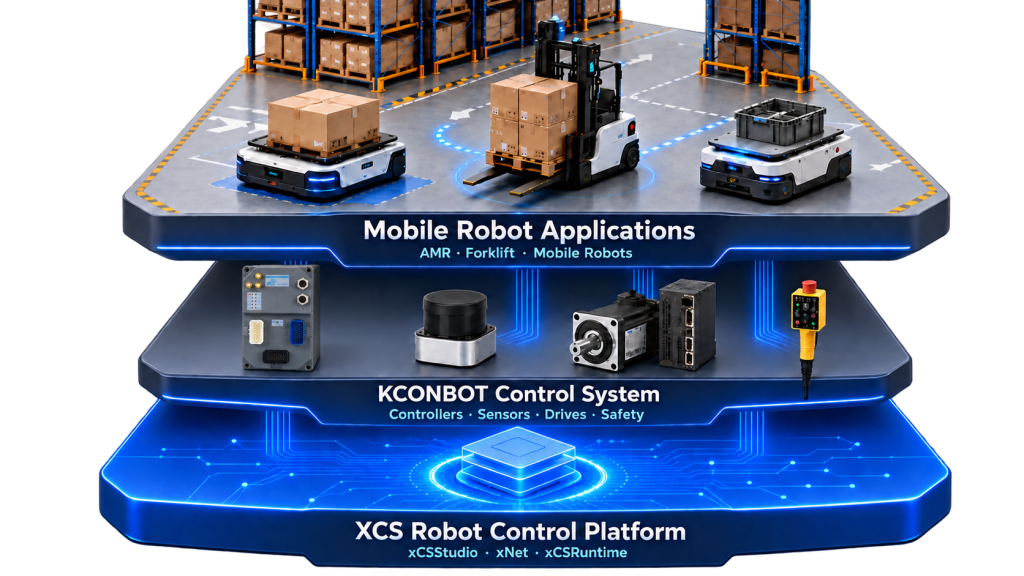
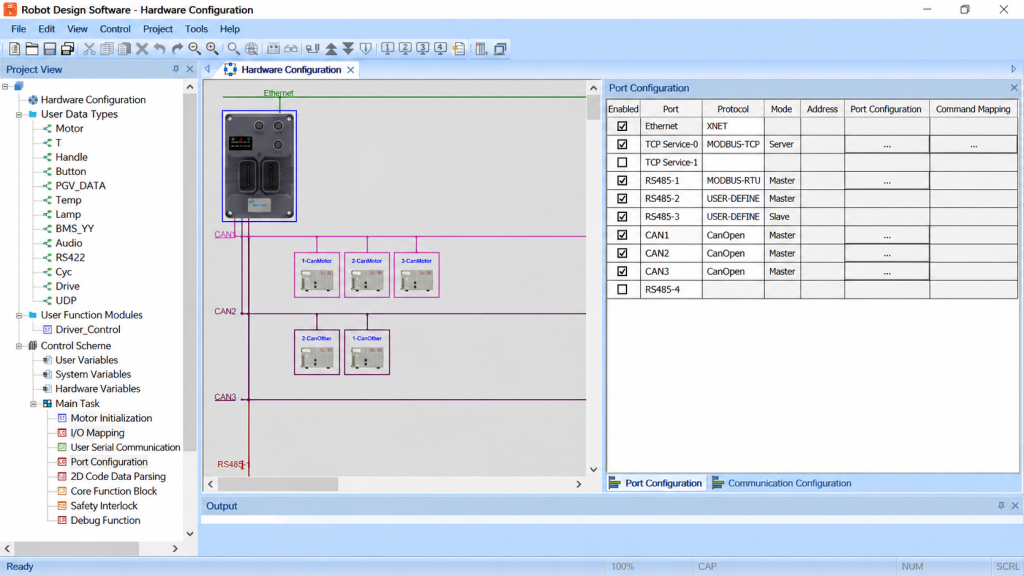
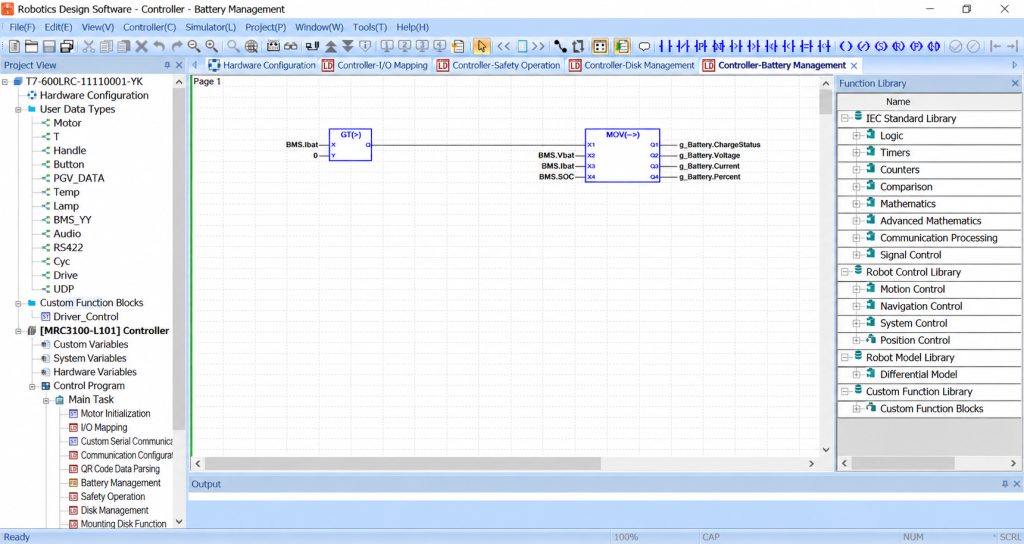
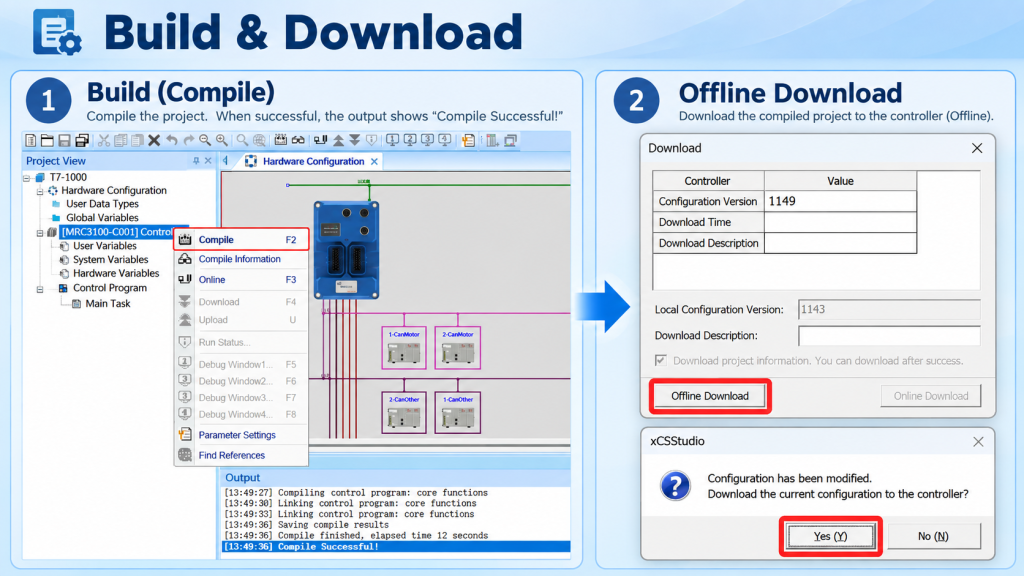
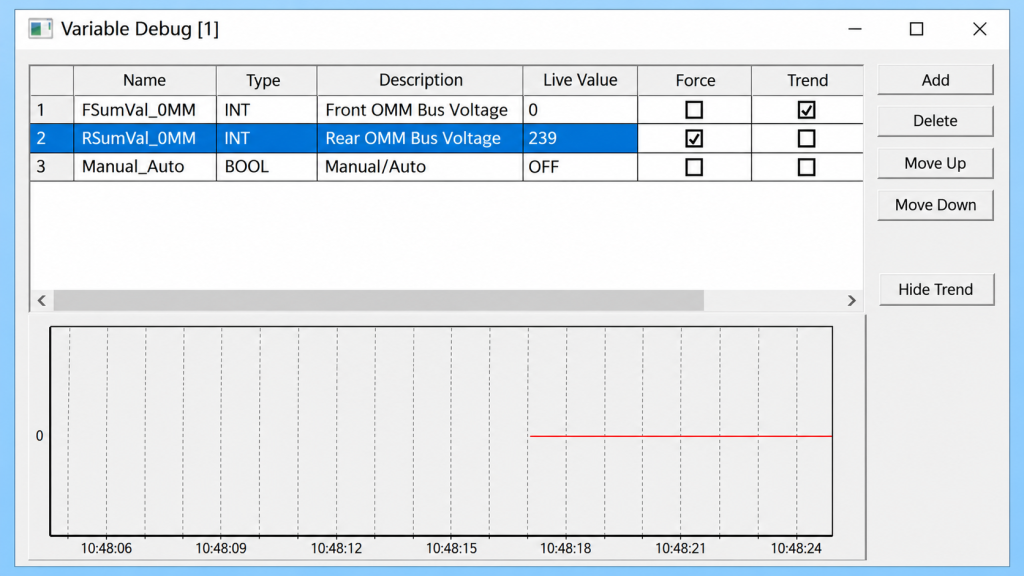
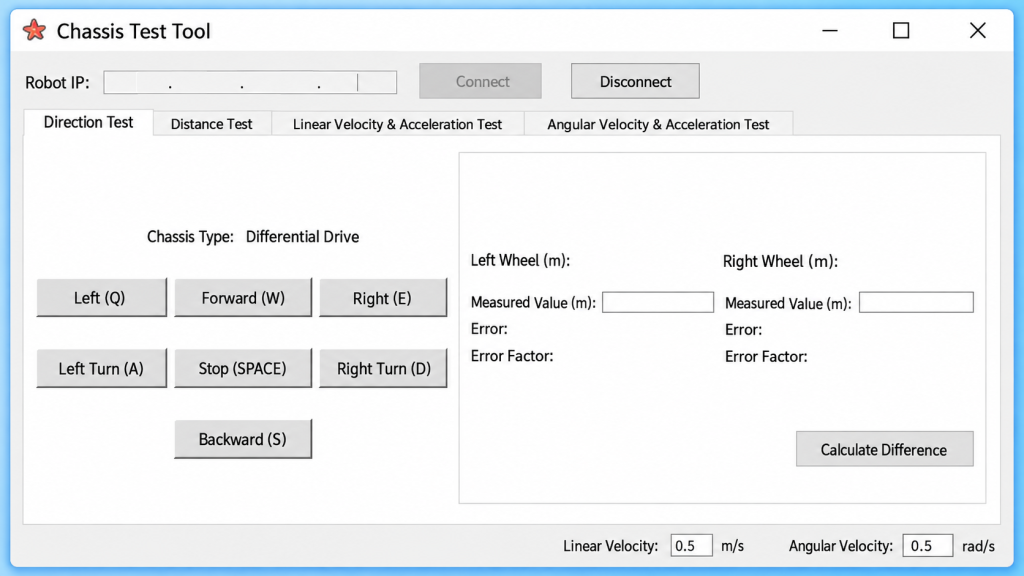
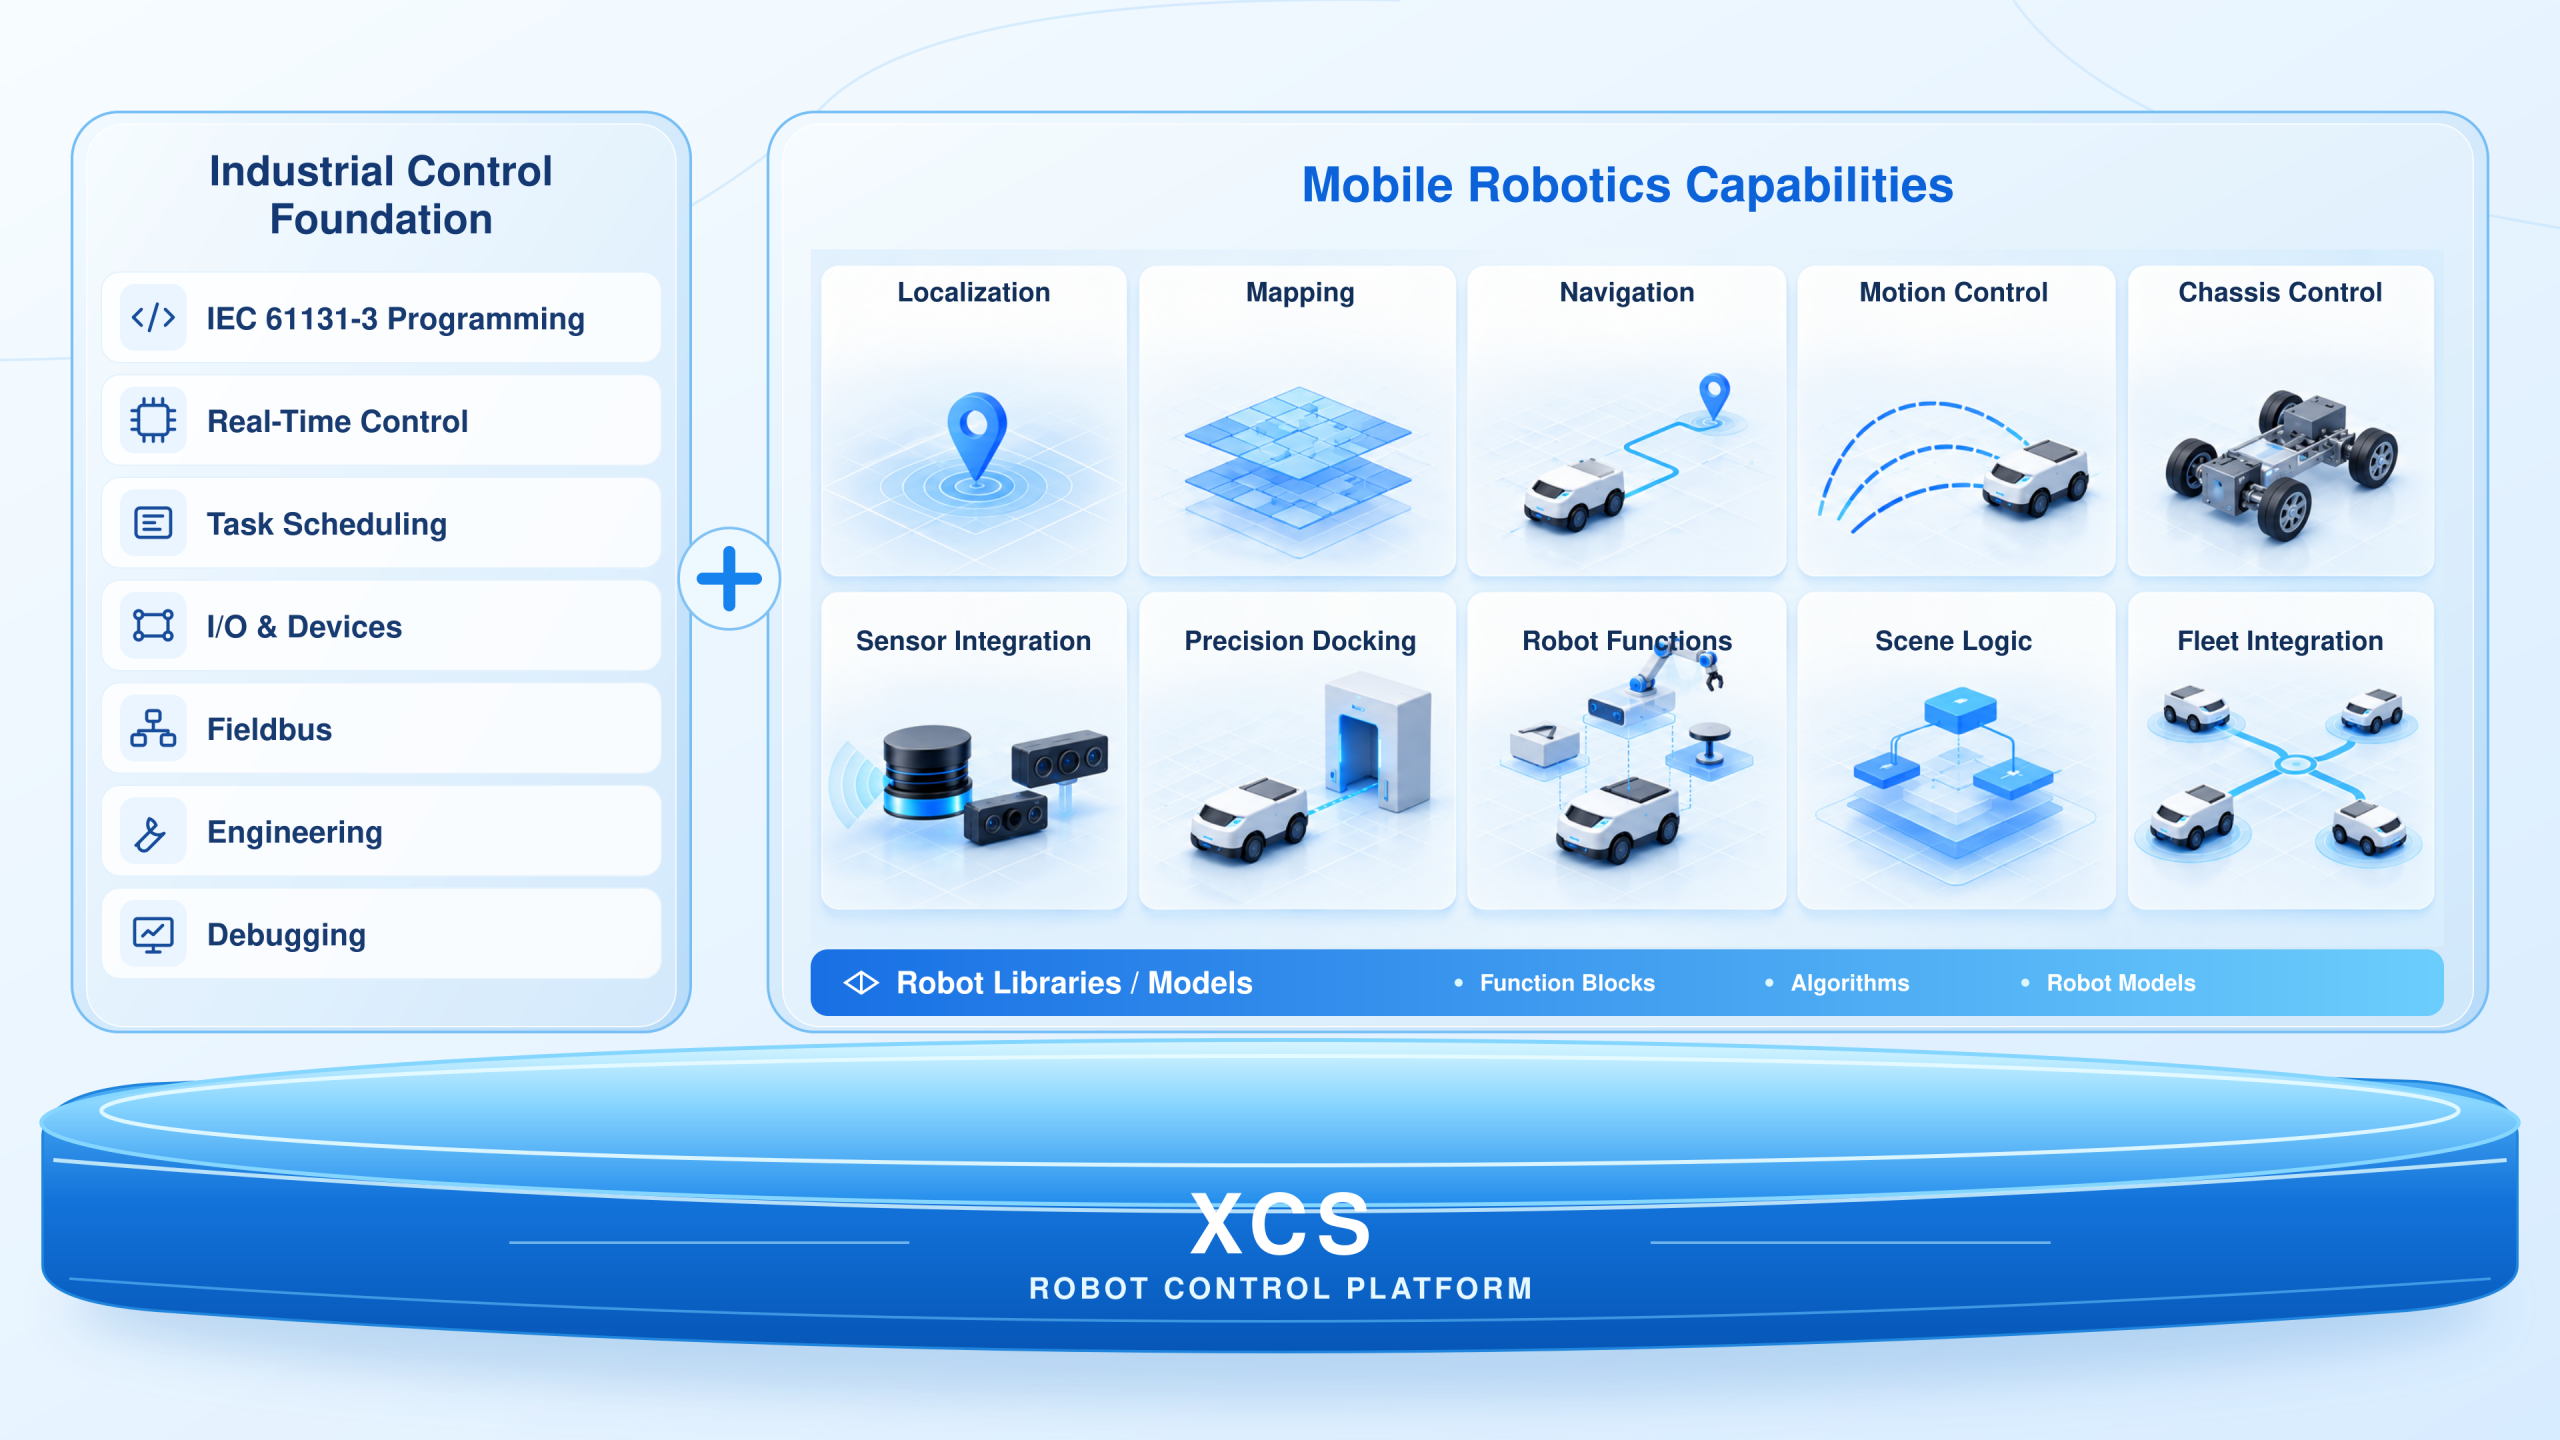
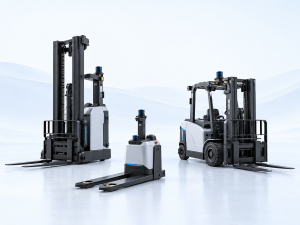
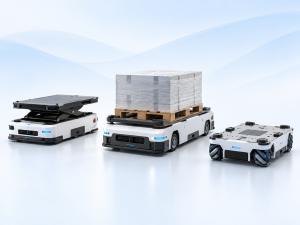
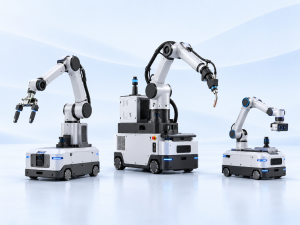
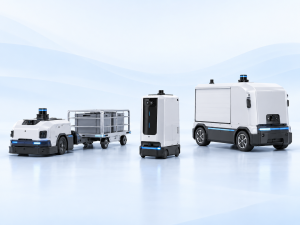
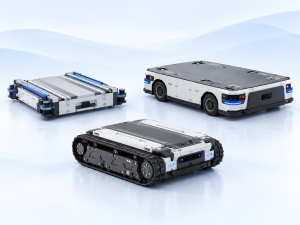
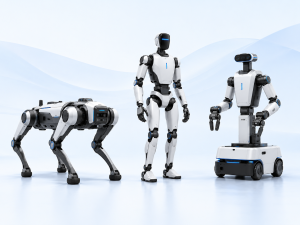
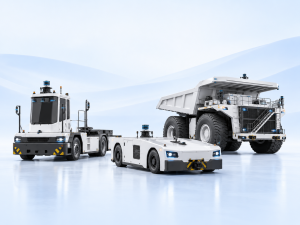
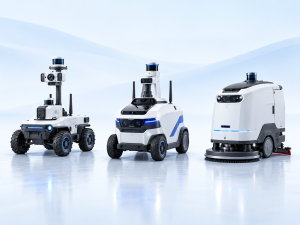
XCS Robot Control Platform The Software Foundation for KCONBOT Mobile Robot Control Systems Platform Architecture Engineering Layer xCSStudio Project Configuration StructureTargetTaskI/ODeviceFieldbusParameter Programming Function BlocksSTRobot LibrariesApplication LogicMotion LogicRobot FunctionsLDFBDVariables Build & Download CheckCompilationCode GenerationDownload Debugger DebugMonitoringWatchRead / Write / ForceTraceSimulationDiagnosis Commissioning ConnectionVerificationTuningTestMonitoringDiagnosisValidation Communication Layer xNet Runtime Layer xCSRuntime Hardware / OS Layer AMR x86 RTOS Linux Windows Built for Mobile Robotics One Platform. Many Robot Types. Autonomous Forklifts Handling & Transfer Robots Mobile Manipulation & Process Robots Towing & Delivery Shuttles & Platforms Legged & Humanoid Robots Industrial / Port / Airport / Mining Vehicles Inspection, Patrol, Service & Cleaning